Sensor Module
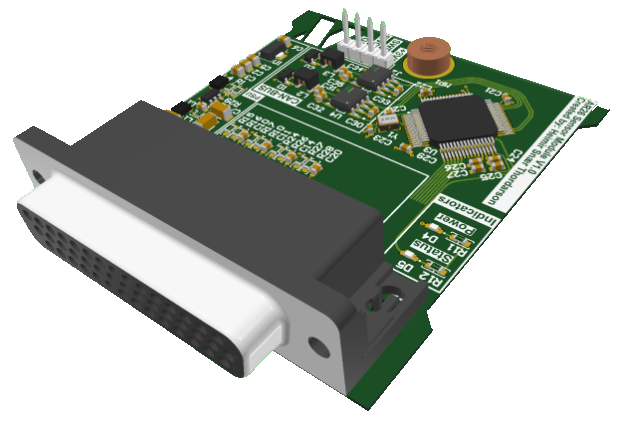
Table of Contents
Description
The Sensor module is designed to measure any extra analog signals rear of the firewall. For AR26, the module is designed to measure two suspension displacement sensors, two oil temperature, four water pressure, four water temperature, and one air temperature sensor. All of the measurements are then transmitted to a CAN network, which there are two of.
Wiring Diagram
In the following section, how the sensor module is connected will be covered. The connector for the sensor module is a High-Density d'sub-44 which is directly solderen onto the circuit board. The plug needed for this system is the 204517-3, which uses crimps instead of solder cups which is common for the dsub connectors
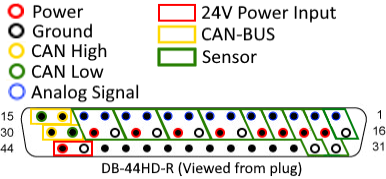
In the figure above, the pinout shows how the pins are divided. Each box shows which pins belong together for each usecase, where the red box is the power input. Yellow boxes are for each canbus network, while the green box is for each sensor used in AR26.
| Pin Number | Pin Name | Type | Pin | Pin name | Type | Pin Number | Pin Name | Pin Type |
|---|---|---|---|---|---|---|---|---|
1 | Air Temperature | Analog (0-3.3V) | 16 | Air Temperature | GND | 31 | Suspension Displacement Left | GND |
| 2 | Suspension Displacement Left | Analog (0-3.3V) | 17 | Suspension Displacement Left | 3V3 | 32 | Suspension Displacement Right | GND |
| 3 | Suspension Displacement Right | Analog (0-3.3V) | 18 | Suspension Displacement Right | 3V3 | 33 | ||
| 4 | Oil Temperature Right | Analog (0-3.3V) | 19 | Oil Temperature Right | 3V3 | 34 | ||
| 5 | Oil Temperature Left | Analog (0-3.3V) | 20 | Oil Temperature Left | 3V3 | 35 | ||
| 6 | Cooling Temperature 4 | Analog (0-3.3V) | 21 | Cooling Sensor 4 | GND | 36 | ||
| 7 | Cooling Pressure 4 | Analog (0-5V) | 22 | Cooling Sensor 4 | 3V3 | 37 | ||
| 8 | Cooling Temperature 3 | Analog (0-3.3V) | 23 | Cooling Sensor 3 | GND | 38 | ||
| 9 | Cooling Pressure 3 | Analog (0-5V) | 24 | Cooling Sensor 3 | 3V3 | 39 | ||
| 10 | Cooling Temperature 2 | Analog (0-3.3V) | 25 | Cooling Sensor 2 | GND | 40 | ||
| 11 | Cooling Pressure 2 | Analog (0-5V) | 26 | Cooling Sensor 2 | 3V3 | 41 | ||
| 12 | Cooling Temperature 1 | Analog (0-3.3V) | 27 | Cooling Sensor 1 | GND | 42 | ||
| 13 | Cooling Pressure 1 | Analog (0-5V) | 28 | Cooling Sensor 1 | 3V3 | 43 | Main Power | GND |
| 14 | CAN High 1 | CAN | 29 | CAN Low 2 | CAN | 44 | Main Power | +24V |
| 15 | CAN Low 1 | CAN | 30 | CAN High 2 | CAN |
Air Temperature Sensor
The air temperature sensor will be used to have a dynamic reference setpoint for the cooling system. This could reduce the current draw from the low voltage system compared to having a fixed reference point. This is because the regulator will not try to cool the water to a temperature lower than the ambient temperature. The sensor works as a resistor which varies depending on its temperature. Where in this case, the resistance lowers when the temperature increases (NTC). To make the microcontroller able to measure the changes in resistance, the thermistor is put into a voltage divider circuit.
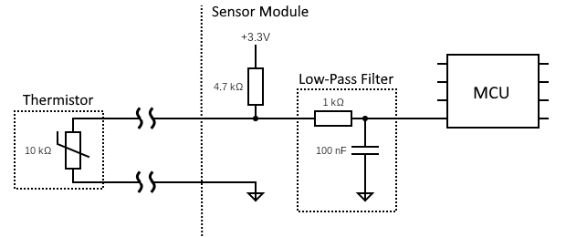
As shown in the figure above, the thermistor is put into a voltage divider circuit with a 4k7 ohm resistor to convert the resistance changes of the thermistor to a measurable voltage. To find the temperature of the thermistor based on the voltage measure by the analog-to-digital converter (ADC), the resistance of the thermistor needs to be calculated based on the voltage from a voltage divider.
Where:
- \(R_f\)= The upper resistor in the voltage divider which stays fixed, which in this case is 4.7k \(\Omega\)
- \(V_{out}\)= The voltage over the thermistor, and the voltage that the microcontroller will measure.
- \(V_{in}\)= The supply voltage of the voltage divider, which in this case is a constant 3.3 \(V\)
- \(R_T\)= Resistance of the thermistor
Knowing this, the resistance of the thermistor can be added into the following equation. This will determine the temperature of the thermistor based on the known resistance and the beta value of the thermistor.
where:
- \(\beta\)= material constant that defines the steepness of its resistance-temperature curve between two temperature points, usually 25/85 degrees celsius. In this case it is 3694 K.
- \(T_0\)= The test temperature at which the thermistor is 10k \(\Omega\), which in this case is 25 degrees celsius.
- \(R_0\)= The resistance of the thermistor when it is 25 degrees celsius.
- \(R_T\)= The live resistance of the thermistor.
Filtering
Considering that the sensor can only promise a reaction time of 5 seconds when in water, it can be assumed that a heavy filter will not add any problematic latencies. To ensure a low cost, the filter uses common components which will filter any noise above the inverter switching noise.
Where:
- \(F_c\)= Cut-off frequency of the filter. Any noise with a frequency above this will be filtered out.
- \(R\)= Resistance of the resistor in low-pass filter.
- \(C\)= Capacitance of the capacitor in the low-pass filter.
Using a resistor with 1k \(\Omega\) and a capacitor with 100 nF in capacitance, the cut-off frequency will be 1592 Hz.
Suspension Displacement Sensor
For AR26, the same sensors from AR25 is reused. These are the Texense RSL-A-50-P which can be connected as the entire voltage divider when using each end as supply and ground. The output of the sensor will then be the throw of the potentiometer.
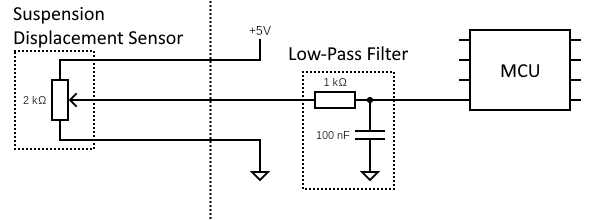
The sensor has a measurable range of 50mm with electrical range of 51mm, meaning that the electrical range will in practice be 1960 \(\Omega\) with 40 \(\Omega\) in total on each end.
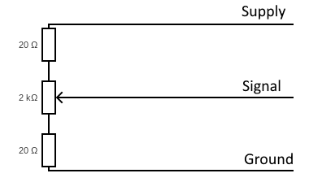
This can then be used to create the length of the sensor based on the input voltage.
where:
- \(x\) = The mechanical placement excluding the dead length (178mm).
- \(V_s\)= The supply voltage of the linear potentiometer, in this case it is 3.3 \(V\).
- \(V_{out}\) = The output voltage of the linear potentiometer. ranging from 0.033\(V\) to 3.267\(V\).
Filtering
The sensors output latency can be expected to be a lot shorter than the air temperature sensor as the sensor is just a variable sensor based on placement. The limiting factor for the system which uses this information is the CAN-BUS messages from the inverters which send the information each 6.25 milliseconds. This means that the cut-off frequency cannot be any lower than 160 Hz, which will make the same type of low pass filter from the air temperature sensor acceptable with a cut-off frequency of 1591 Hz.
Gearbox Temperature Sensor
The gearbox Temperature Sensor for AR26 will be the GAG10K3976B1, a NTC temperature probe which will be installed into a generic M5 bolt which is mounted on the upright in the wheel assembly. The thermistor will be connected in a voltage divider configuration where the thermistor is in the lower position so that the voltage lowers when the temperature increases.
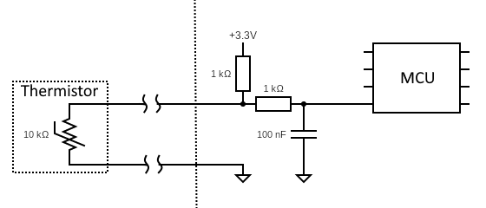
Knowing the beta constant of the thermistor, the equation for the temperature based on the voltage measured by the ADC inside microcontroller can be derived.
Where:
- \(R_f\)= The upper resistor in the voltage divider which stays fixed, which in this case is 1k \(\Omega\)
- \(V_{out}\)= The voltage over the thermistor, and the voltage that the microcontroller will measure.
- \(V_{in}\)= The supply voltage of the voltage divider, which in this case is a constant 3.3 \(V\)
- \(R_T\)= Resistance of the thermistor
Knowing this, the resistance of the thermistor can be added into the following equation. This will determine the temperature of the thermistor based on the known resistance and the beta value of the thermistor.
where:
- \(\beta\)= material constant that defines the steepness of its resistance-temperature curve between two temperature points, usually 25/85 degrees celsius. In this case it is 3976 K.
- \(T_0\)= The test temperature at which the thermistor is 10k \(\Omega\), which in this case is 25 degrees celsius.
- \(R_0\)= The resistance of the thermistor when it is 25 degrees celsius.
- \(R_T\)= The live resistance of the thermistor.
Filtering
The sensors output latency can be expected to be a lot shorter than the oil temperature sensor as the sensor is just a variable sensor based on placement. The limiting factor for the system which uses this information is the CAN-BUS messages from the inverters which send the information each 6.25 milliseconds. This means that the cut-off frequency cannot be any lower than 160 Hz, which will make the same type of low pass filter from the oil temperature sensor acceptable with a cut-off frequency of 1591 Hz.